ZJU-UIUC Institute
B.E. in Mechanical Engineering · GPA: 3.97/4.3
Humanoids will bear witness to true intelligence.
I am a first-year Ph.D. student in the College of Control Science and Engineering at Zhejiang University, advised by Prof. Liangjing Yang and co-advised by Prof. Zhongyu Li at The Chinese University of Hong Kong (CUHK). My collaborating advisor is Prof. Chao Xu at ZJU FAST-Lab.
My former Ph.D. advisor was Prof. Hua Chen, now Full-Time CTO at LimX Dynamics.
I am currently an intern at Mondo Robotics, mentored by Shuo Yang.
I am fortunate to work with Leixin Chang, whose guidance has been invaluable at the beginning of my academic journey.
My research interests lie in humanoid loco-manipulation: how to bridge high-level behavior cloning (BC) with low-level dynamics.
My Cat Xixi(希希) — “hope” in Chinese.
B.E. in Mechanical Engineering · GPA: 3.97/4.3
B.E. in Mechanical Engineering · GPA: 3.92/4.0

Ph.D. in Control Science and Engineering

Yuxuan Nai, Leixin Chang, Liangjing Yang†, Shuo Yang†, Zhongyu Li†
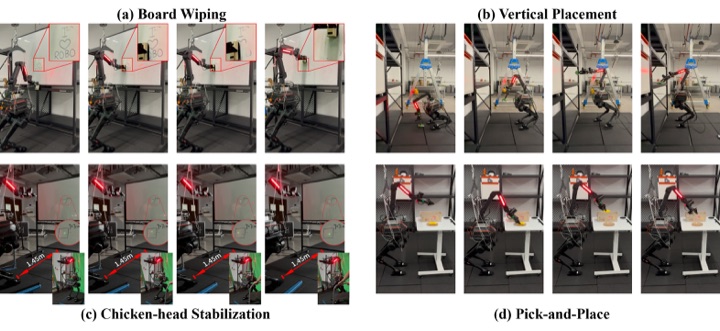
Zhongyu Chen*, Yuxuan Nai*, Qian Chen, Yidong Zhu, Chen Jing, Qihan Wang, Xudong Li, Zhizhan Li, Leixin Chang, Liangjing Yang, Hua Chen

Yuxuan Nai, Ding Jiang, Ziyin Han, Chengyu Yang, Sheng Cheng†, Naira Hovakimyan†

Leixin Chang, Yuxuan Nai, Hua Chen†, Liangjing Yang†
Unified locomotion policy and terrain-aware parkour for the A3 humanoid.
Founded and led the institute's first photography club.